RESEARCHING DYNAMICS OF THE INTERACTION BETWEEN PEOPLE AND AUTONOMOUS SYSTEMS
Systems and control theory · Human modeling · Human–AI interaction
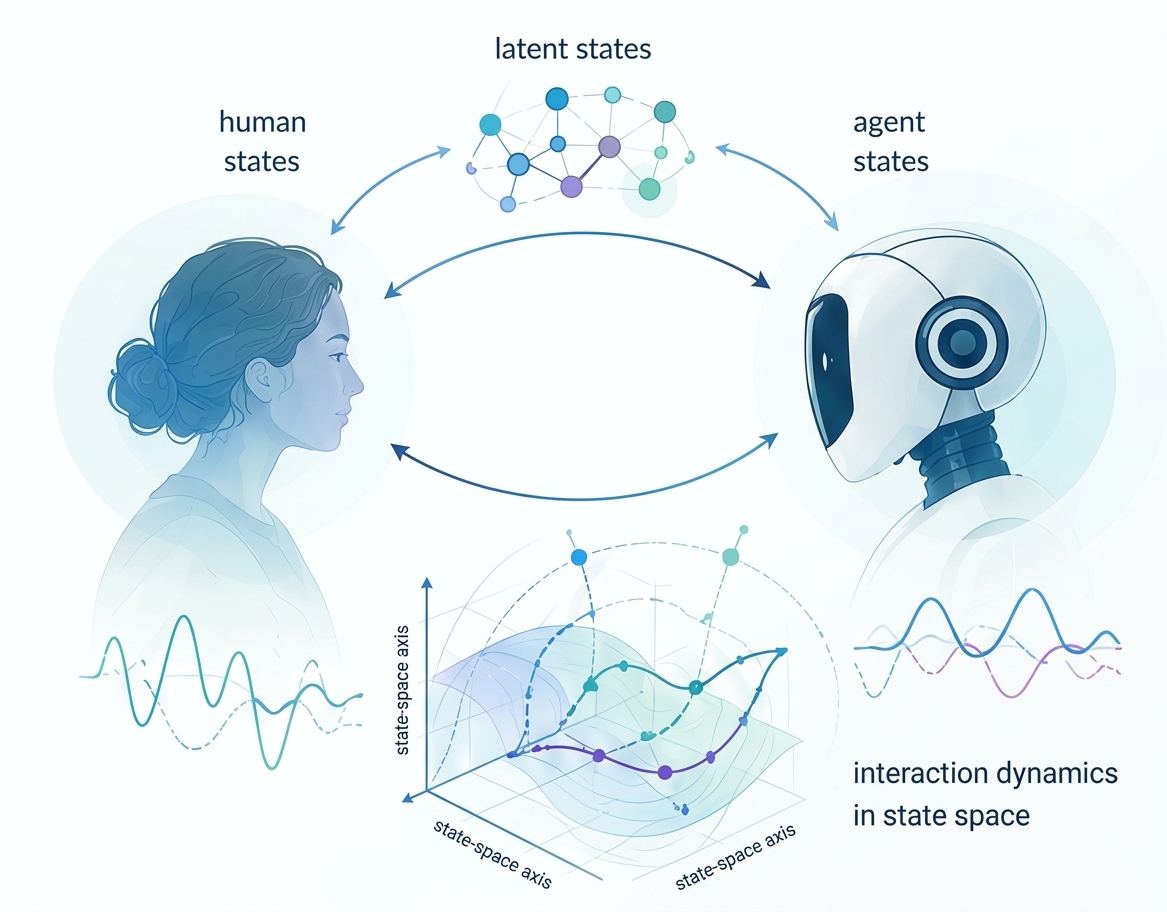
I develop mathematical and control-theoretic methods for autonomous decision-making under uncertainty, with a particular focus on systems that interact with humans. My research connects systems and control theory, mathematical modeling of human behavior, and adaptive autonomous systems, from foundational theory to applications in robotics and human–AI interaction.
THE RESEARCH LOGIG


1. Model human cognition
Mathematically model perception, cognition and decision-making under uncertainty.
2. Reconstruct relevant states
Estimate latent human states from
interaction signals and finite histories.
3. Predict coupled dynamics
Characterize how human and AI actions
shape each other’s latent states and signals.
4. Regulate interaction under constraints
Establish constrained AI actions to achieve
stable and predictable interaction.
THREE CONNECTED RESEARCH STRANDS
| STRAND 1 Mathematical decision-making under uncertainty Control-theoretic and optimization methods for autonomous decision-making in dynamic, uncertain environments. 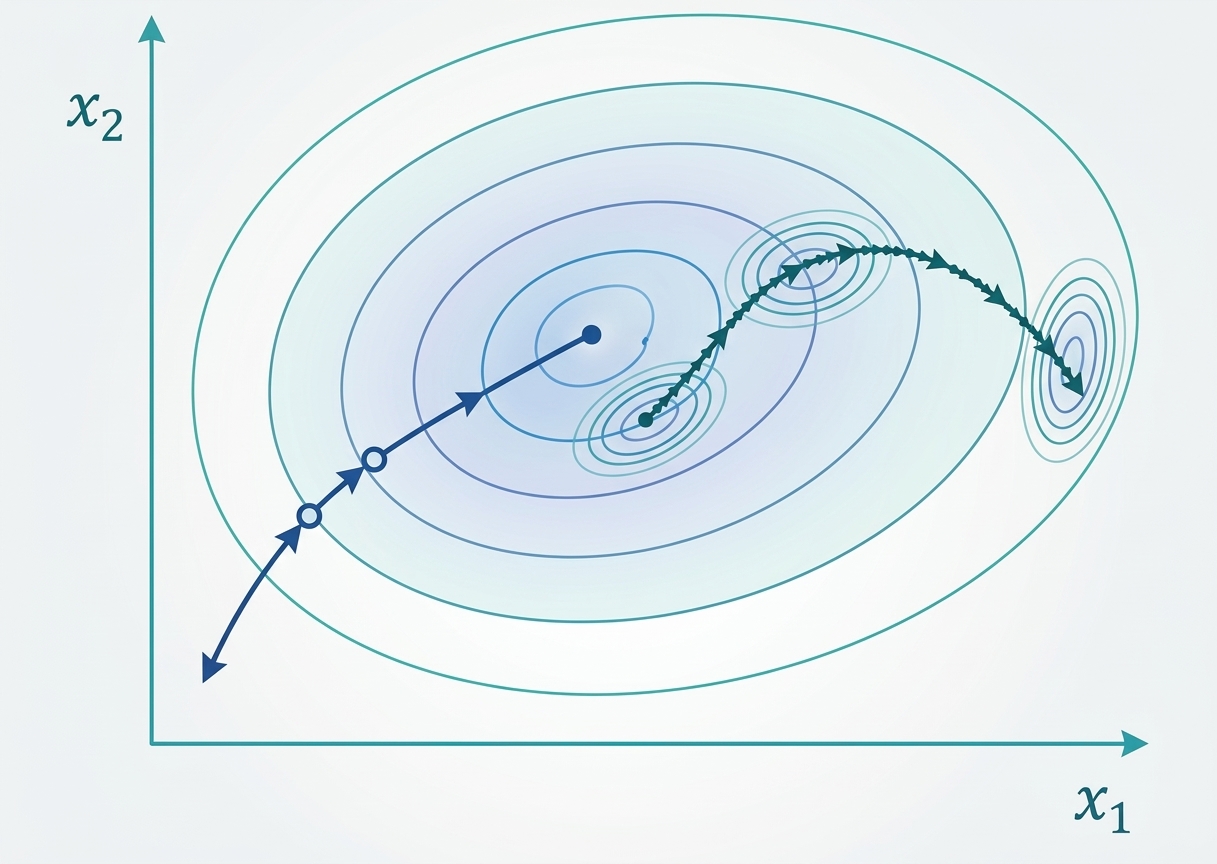 | STRAND 2 Human-state modeling and reconstruction Dynamic models of human perception, cognition and decision processes, and methods to recover latent states from interaction signals. 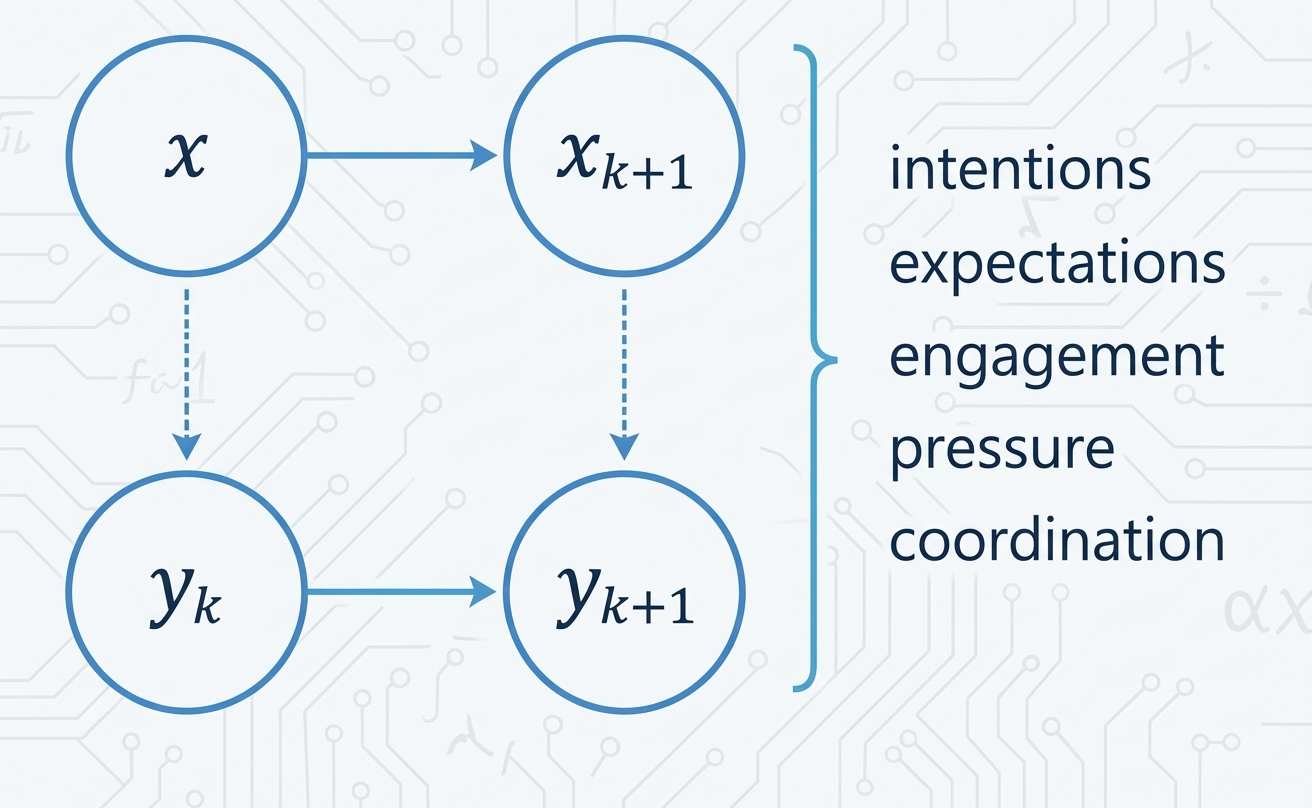 | STRAND 3 Prediction and regulation of human–AI interaction Models and control methods for predicting and regulating coupled human–AI dynamics under constraints and uncertainties. 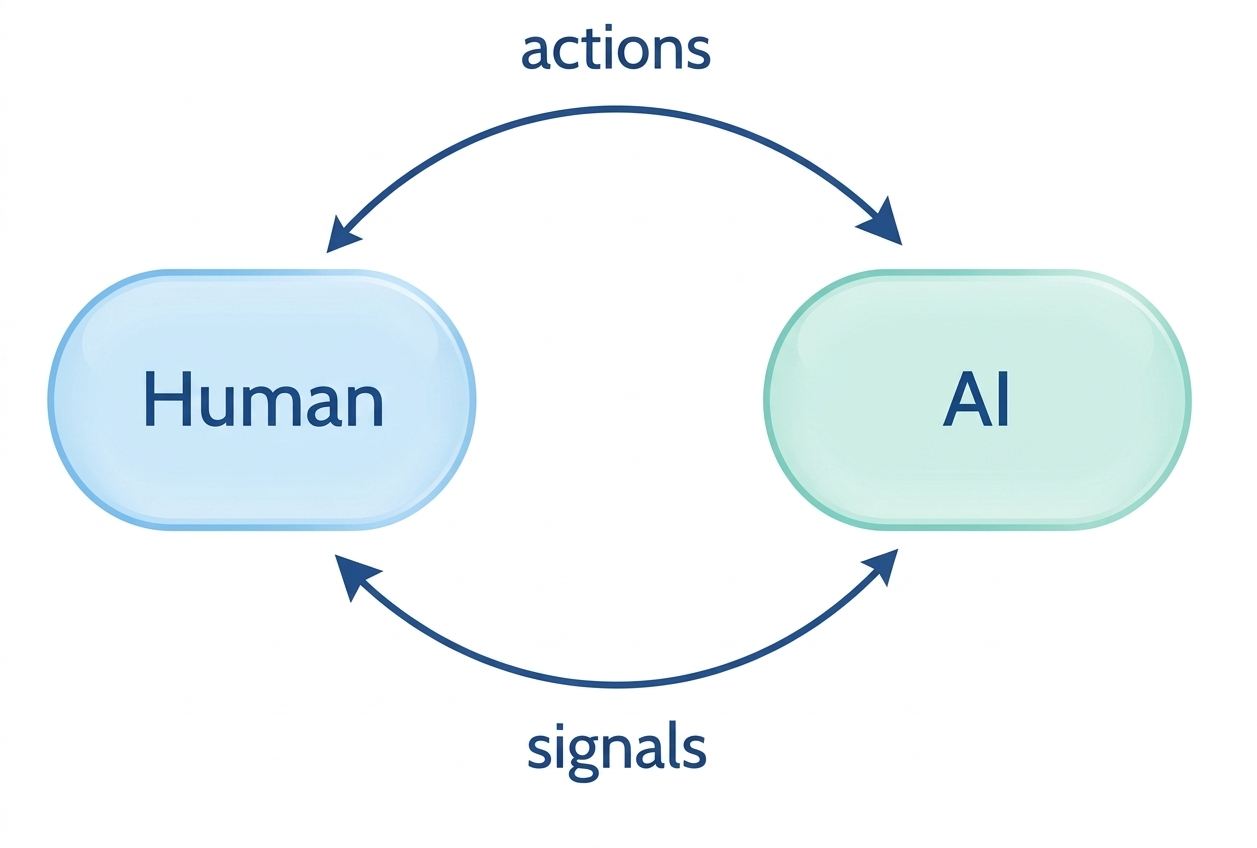 |
FROM THEORY TO ACTUAL SYSTEMS
My methods and findings inform real-world applications in human-centered autonomous systems.
 Search and rescue robotics Robots that assist in complex and human-centered environments. |  Social robotics Robots that communicate, collaborate and adapt to human behavior. |  Autonomous Decision Systems Safe and reliable decision-making under uncertainty and constraints. |