Anahita Jamshidnejad
Assistant Professor · Delft University of Technology
Founder of Mathematical Decision Making Group
Co-founder and co-director of AI*MAN Lab
My research develops mathematical and control-theoretic methods for autonomous decision-making under uncertainty, with a particular focus on systems that interact with humans.
I study how human perception, cognition and decision-making can be represented dynamically, how latent human states (e.g., emotions, goals, trust, …) can be reconstructed from interaction signals, and how autonomous agents can use such models to predict and regulate their interactions with people.
My work connects systems and control theory, mathematical modeling of human cognition and behavior, and adaptive autonomous systems. It spans foundational methods for prediction and constrained decision-making as well as applications in robotics and human–AI interaction.
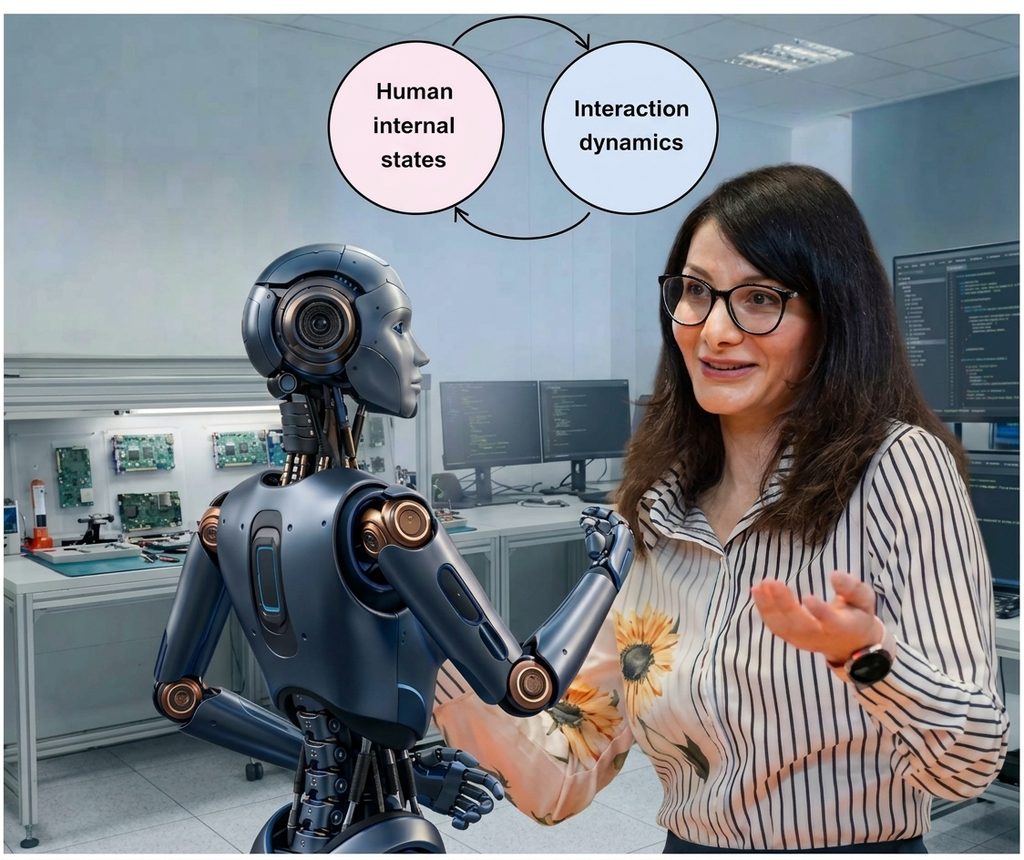
for safer, more cooperative human–AI systems.
From human decision-making to regulated interaction dynamics
|
1. Mathematical decision-making Control-theoretic and optimization methods for decision-making under uncertainty. | 2. Human state modeling Dynamic models of human perception, cognition and decision processes. | 3. State reconstruction and prediction Recovering latent human states from interaction signals and predicting coupled dynamics. | 4. Constrained control and regulation Adaptive and safe AI actions for predictable, stable and cooperative interactions. | 5. Real-world validation Experiments with virtual and robotic systems to evaluate theory and identify limits. |
Selected Publications
| State-dependent dynamic tube MPC International Journal of Robust and Nonlinear Control · 2025 | Fuzzy-Logic-based model predictive control Applied Soft Computing · 2026 | SONAR: A control architecture for social norm aware robots International Journal of Social Robotics · 2024 | Leveraging systems and control theory for social robotics Applied Intelligence · 2026 |